

Python: Camera Lens Calibration#
This example renders the robot-lineup scene from separate OpenCV pinhole, OpenCV fisheye, and omni-directional stereo RenderProducts. It logs all three images to Rerun and can save individual PNGs plus a contact sheet.
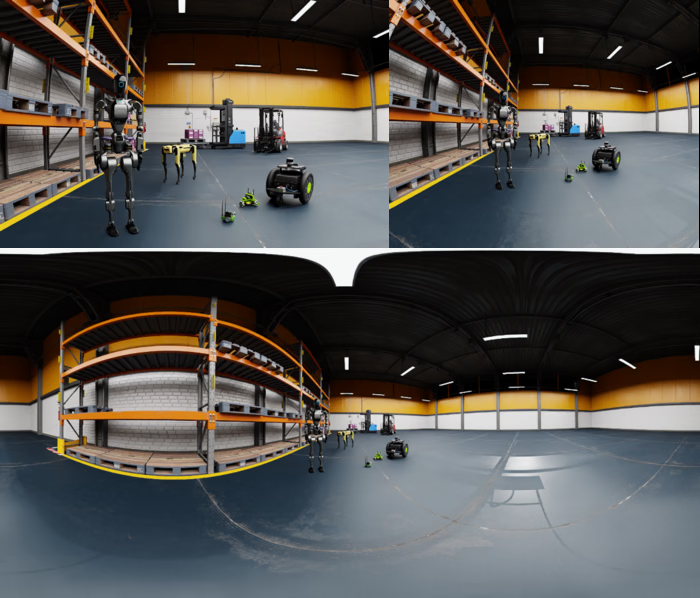
Three camera views of the same scene showing three different lens calibration schemata. Clockwise from top-left: OmniLensDistortionOpenCvPinholeAPI, OmniLensDistortionOpenCvFisheyeAPI, OmniLensDistortionOmniDirectionalStereoAPI#
cd examples/python/camera-lens-calibration
uv run main.py
uv run main.py --rrd _output/camera-lens-calibration.rrd
uv run main.py --no-rr --png _output/camera-lens-calibration.png
See Lens Calibration for the authoring model.