

Lens Calibration#
Overview#
Lens-distortion API schemas let a camera reproduce measured camera intrinsics and distortion. ovrtx supports OpenCV pinhole and fisheye calibration, lookup-table-based generalized projection, and omni-directional stereo.
When you apply one of these schemas, its calibration parameters drive
projection instead of focalLength and the aperture attributes. Depth of
field still uses focalLength, focusDistance, and fStop.
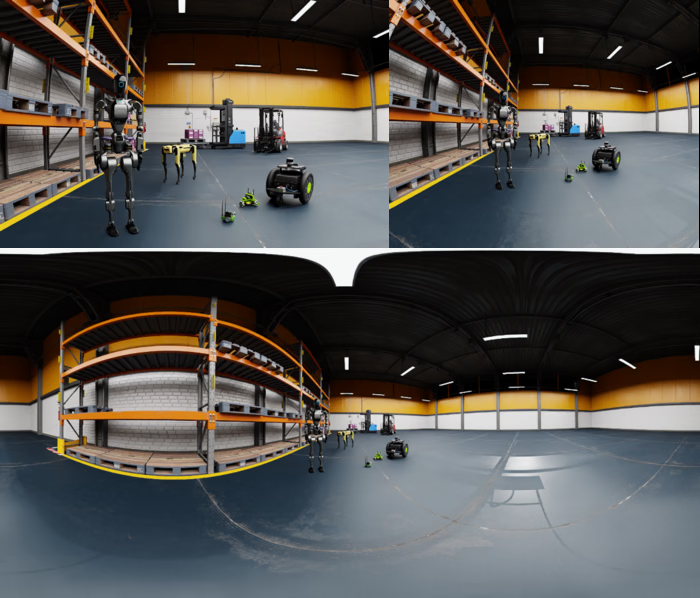
Three camera views of the same scene showing three different lens calibration schemata. Clockwise from top-left: OmniLensDistortionOpenCvPinholeAPI, OmniLensDistortionOpenCvFisheyeAPI, OmniLensDistortionOmniDirectionalStereoAPI#
Creating A Calibrated Camera#
Apply one lens-distortion API schema to a Camera prim. The following
examples create the same OpenCV pinhole calibration.
def Camera "Camera" (
    prepend apiSchemas = ["OmniLensDistortionOpenCvPinholeAPI"]
)
{
    token omni:lensdistortion:model = "opencvPinhole"
    float omni:lensdistortion:opencvPinhole:cx = 1024
    float omni:lensdistortion:opencvPinhole:cy = 512
    float omni:lensdistortion:opencvPinhole:fx = 900
    float omni:lensdistortion:opencvPinhole:fy = 800
    int2 omni:lensdistortion:opencvPinhole:imageSize = (2048, 1024)
    float omni:lensdistortion:opencvPinhole:k1 = 0
    float omni:lensdistortion:opencvPinhole:k2 = 0
    float omni:lensdistortion:opencvPinhole:p1 = 0
    float omni:lensdistortion:opencvPinhole:p2 = 0
}
prim = UsdGeom.Camera.Define(stage, "/Camera").GetPrim()
prim.ApplyAPI("OmniLensDistortionOpenCvPinholeAPI")
prim.GetAttribute("omni:lensdistortion:model").Set("opencvPinhole")
prim.GetAttribute("omni:lensdistortion:opencvPinhole:imageSize").Set(Gf.Vec2i(2048, 1024))
for name, value in {
    "fx": 900.0,
    "fy": 800.0,
    "cx": 1024.0,
    "cy": 512.0,
    "k1": 0.0,
    "k2": 0.0,
    "p1": 0.0,
    "p2": 0.0,
}.items():
    prim.GetAttribute(f"omni:lensdistortion:opencvPinhole:{name}").Set(value)
See Python: Camera Lens Calibration for a runnable example.
Available Schemas#
Applied API schema |
Purpose |
|---|---|
|
Uses OpenCV pinhole projection with radial, tangential, and thin-prism coefficients. |
|
Uses OpenCV fisheye projection with four radial coefficients. |
|
Defines projection with ray-direction and ray-position textures. |
|
Renders one eye of a 360-degree stereo projection. |
|
Preserves calibration data that uses the NVIDIA f-theta model. |
|
Preserves calibration data that uses the Kannala-Brandt K3 model. |
|
Preserves calibration data that uses the radial-tangent thin-prism model. |
For new calibrated cameras, prefer the OpenCV, LUT, or omni-directional stereo schemas. Use the compatibility schemas when preserving existing calibration data.
OpenCV Pinhole#
USD declaration |
Description |
|---|---|
|
Selects OpenCV pinhole projection. |
|
Calibration resolution in pixels. |
|
Horizontal focal length in calibration pixels. |
|
Vertical focal length in calibration pixels. |
|
Horizontal principal point in calibration pixels. |
|
Vertical principal point in calibration pixels. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Tangential coefficient. |
|
Tangential coefficient. |
|
Thin-prism coefficient. |
|
Thin-prism coefficient. |
|
Thin-prism coefficient. |
|
Thin-prism coefficient. |
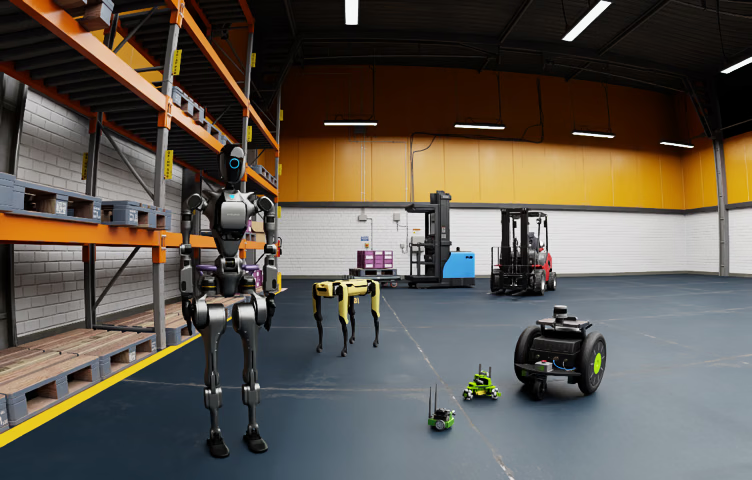
OpenCV pinhole projection with radial and tangential distortion.#
OpenCV Fisheye#
USD declaration |
Description |
|---|---|
|
Selects OpenCV fisheye projection. |
|
Calibration resolution in pixels. |
|
Horizontal focal length in calibration pixels. |
|
Vertical focal length in calibration pixels. |
|
Horizontal principal point in calibration pixels. |
|
Vertical principal point in calibration pixels. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
|
Radial coefficient. |
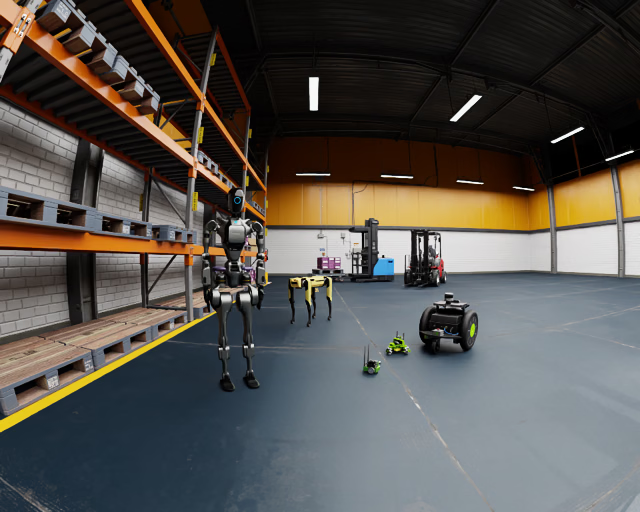
OpenCV fisheye projection using four equidistant distortion coefficients.#
imageSize makes an OpenCV calibration independent of output resolution.
When the RenderProduct resolution differs, ovrtx scales fx, fy, cx,
and cy to the output resolution.
Generalized Projection#
OmniLensDistortionLutAPI defines non-parametric projection with two
floating-point textures.
USD declaration |
Description |
|---|---|
|
Selects lookup-table projection. |
|
Calibrated sensor width. |
|
Calibrated sensor height. |
|
Optical center in calibrated sensor coordinates. |
|
RGB image whose values contain normalized XYZ ray directions in camera space. |
|
RGB image whose RG channels contain normalized screen-space ray origins. |
Warning
Low-resolution lookup textures can produce artifacts at larger output resolutions. Supported file formats, filtering, and failure behavior still need a portable public runtime test. The example on this page validates the OpenCV models, not LUT projection.
Omni-Directional Stereo#
OmniLensDistortionOmniDirectionalStereoAPI configures one eye of a
360-degree stereo camera. Use separate left- and right-eye cameras.
USD declaration |
Description |
|---|---|
|
Selects omni-directional stereo projection. |
|
Selects the left eye when true and the right eye when false. |
|
Eye separation in meters. |
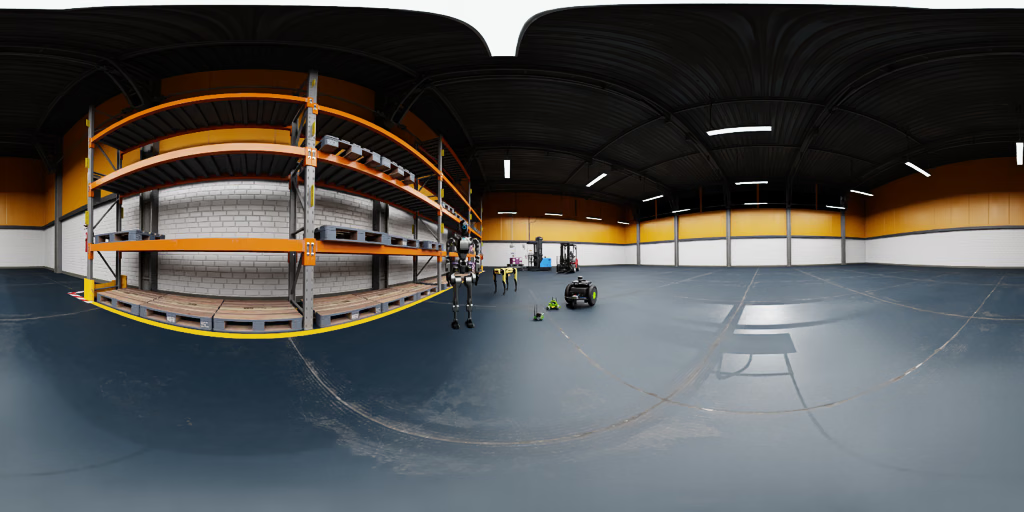
A 1024 by 512 single-eye omni-directional stereo panorama.#